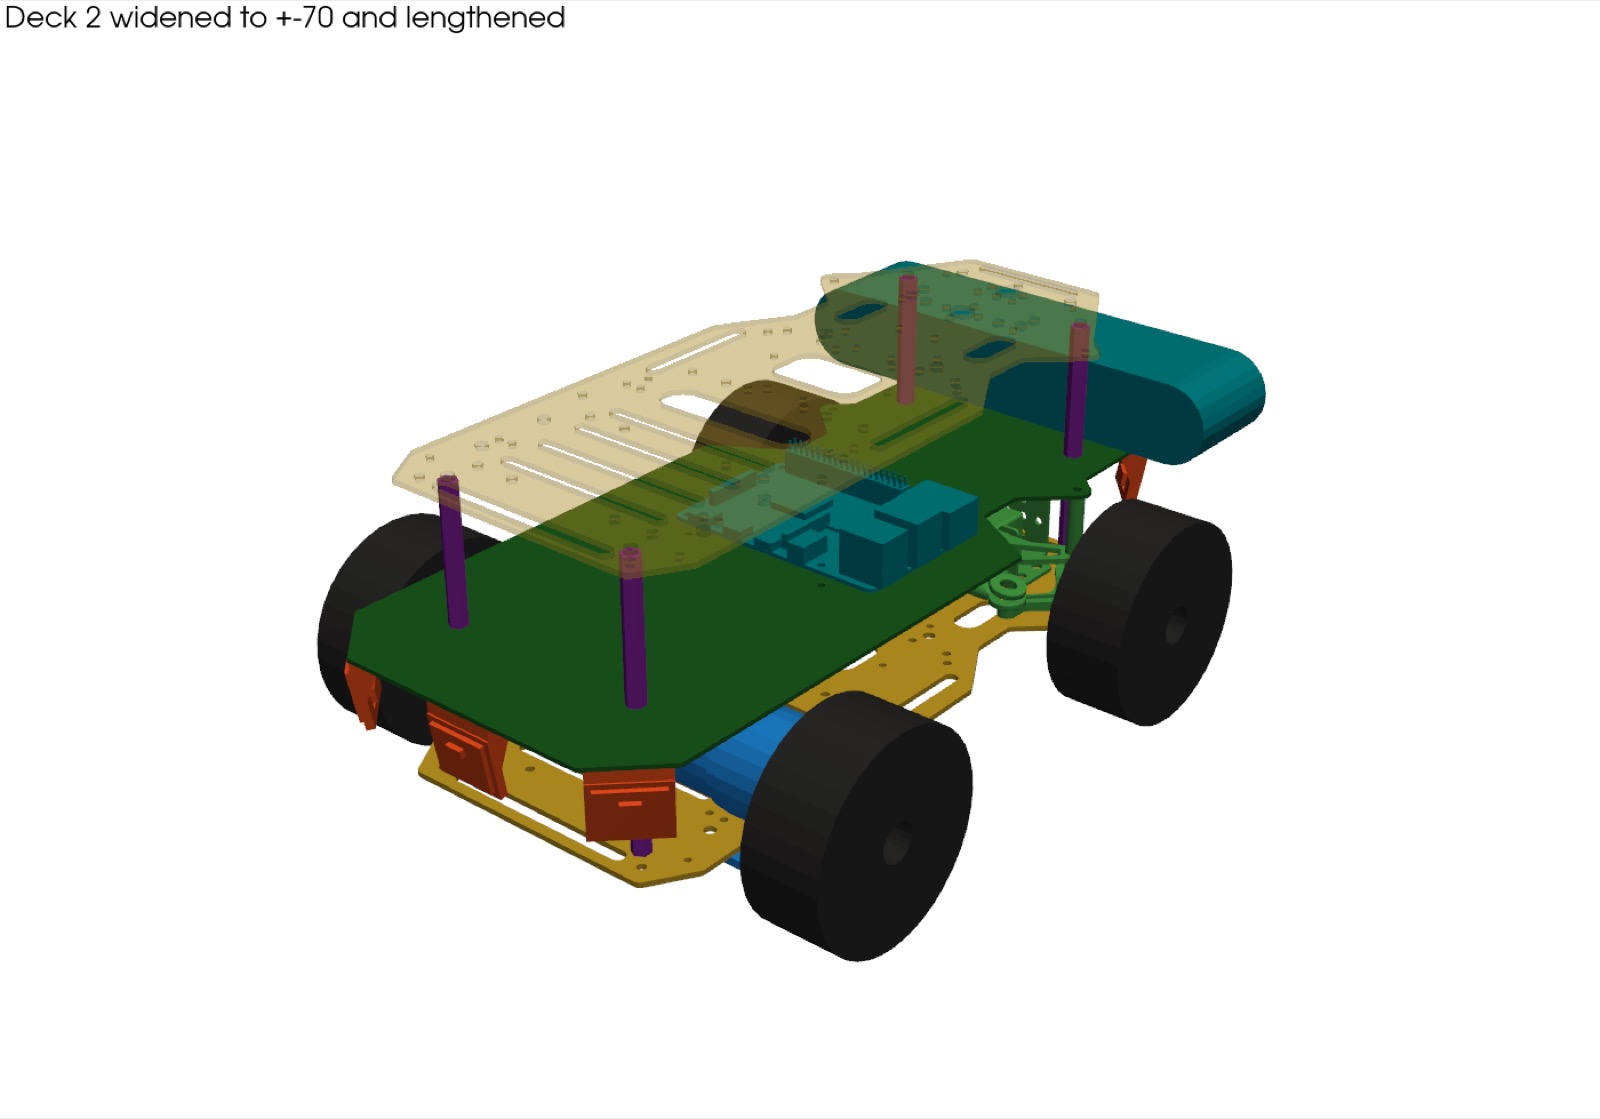
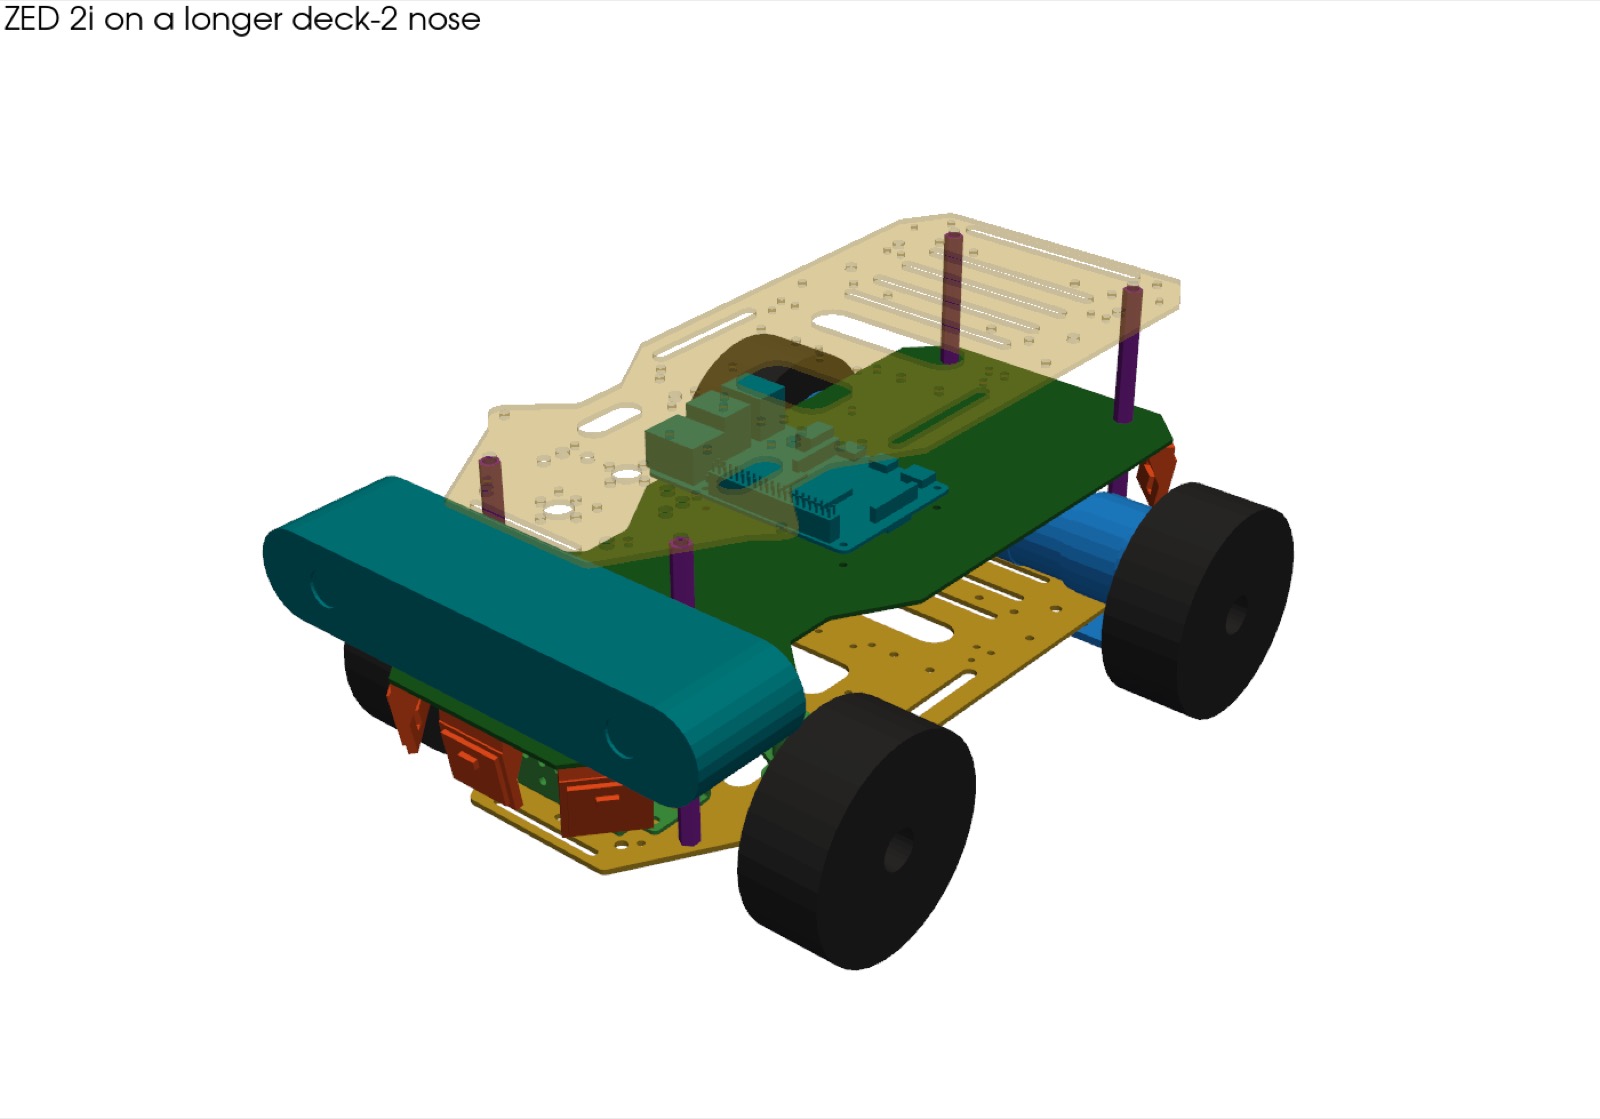
Now agents change the robot's design. The chassis STEP was split into 134 named parts, and everything of mine is Python code, so any change can be built, measured and checked for collisions in a couple of seconds.
The coolest part is the proximity sensors. I said "I want 8 around the robot", and Claude wrote a ray tracer: from every point of the board edge it casts the sensor's 8x8 zones through the whole model, with the wheels steered ±30°. The sides turned out 20-100% blocked by wheels, gearboxes and steering links, so 6 sensors remained: front and rear centre and on the chamfers. Then I said "I want the brackets to sit square on the edge", and the board changed shape: the chamfers turned to face the sensors, the nose grew 21 mm for the ZED 2i camera and the tail 23 mm.