I wanted to move to BLDC motors so the robot would drive faster and quieter. One condition: drop-in, fitting the stock 37D brackets without rework.
- with Claude I went through everyone who makes 37 mm BLDC motors. Nothing fits "like the original" with an A/B encoder: the Chinese JGB37 BLDC ones come with Hall sensors only, and Hiwonder doesn't sell them at all
- from maxon we downloaded the whole 73 MB catalogue and parsed every motor, gearhead and encoder into JSON to find a combination for 1.25 m/s. The winner was ECX FLAT 22 + GPX 22 + ENX 22, but that's €430 each plus an adapter plate that has to be milled
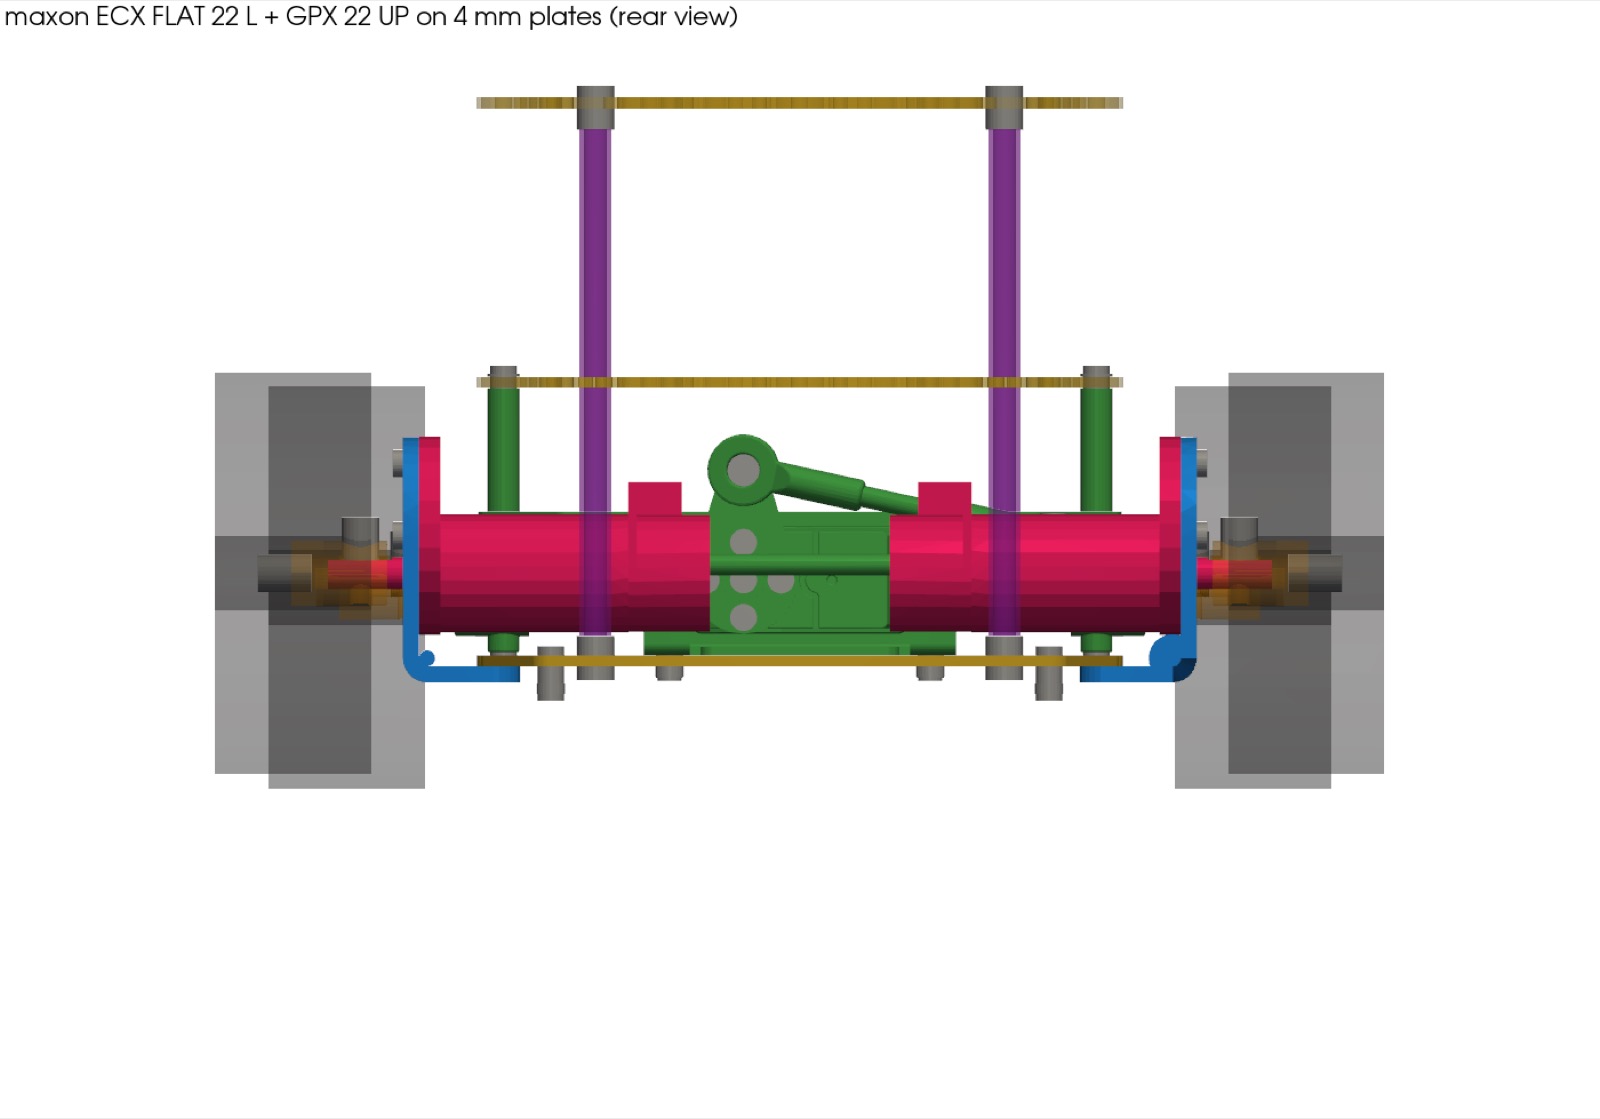
- we put the maxon into the robot's 3D model and checked the clearance to the deck: 4.3 mm, it fits
Then I worked out that for a flat the stock motors already do 1.25 m/s. I went back to the stock JGB37 and simply threw out the RoboClaw: the motors are now driven by my own board.