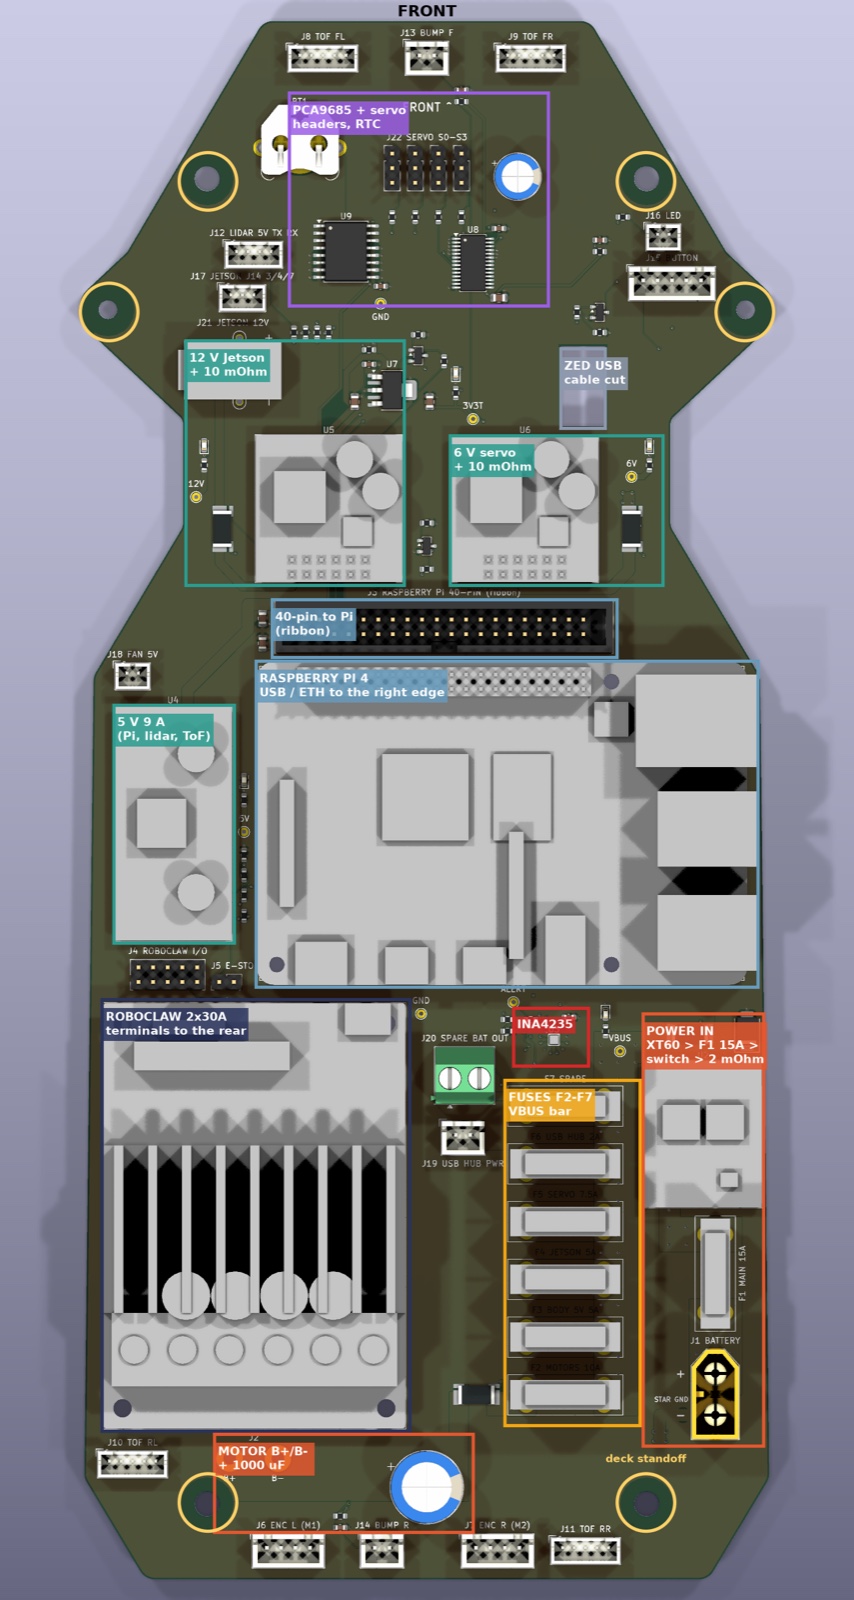
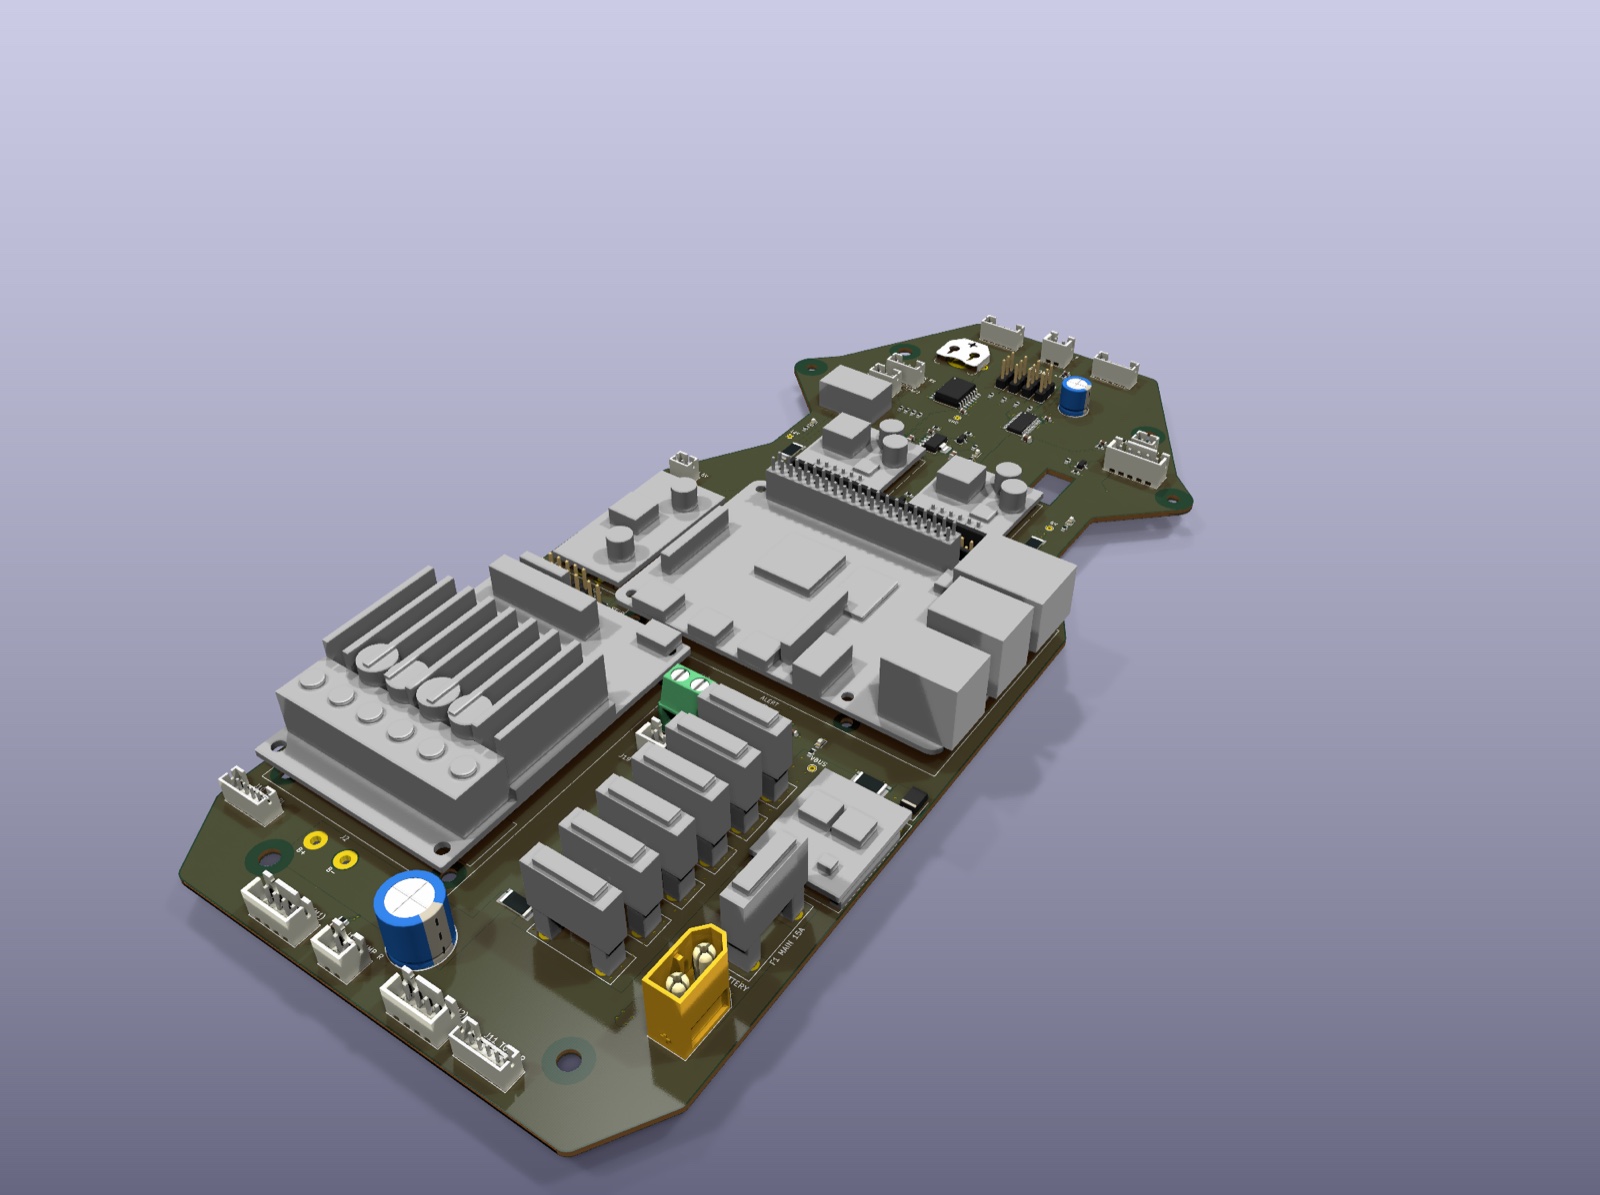
The robot's middle deck won't be acrylic with a pile of modules and wires anymore, but a PCB of the same shape. The outline and standoff holes were taken straight from the chassis 3D model, so it drops in where the acrylic was.
On the board: the Raspberry Pi, the RoboClaw, step-downs, a fuse per branch, an INA4235 with shunts, a PCA9685 for steering, a clock and all the connectors along the edges, each facing its device. The bottom is empty, that's where the Jetson and the motors are. 4 layers, the battery path carries ~16 A.
The coolest part is that nobody drew it with a mouse. The board is described in Python, KiCad builds it from the script, Freerouting routes the signals, and kicad-cli does the checks and the factory files. Change something in the code, rerun, get a new board. 5 boards with assembly at JLCPCB come to ~$200-260.
The motor section is deliberately kept in one corner: I want to move to BLDC motors and later replace the RoboClaw with a controller right on the board without moving everything else.