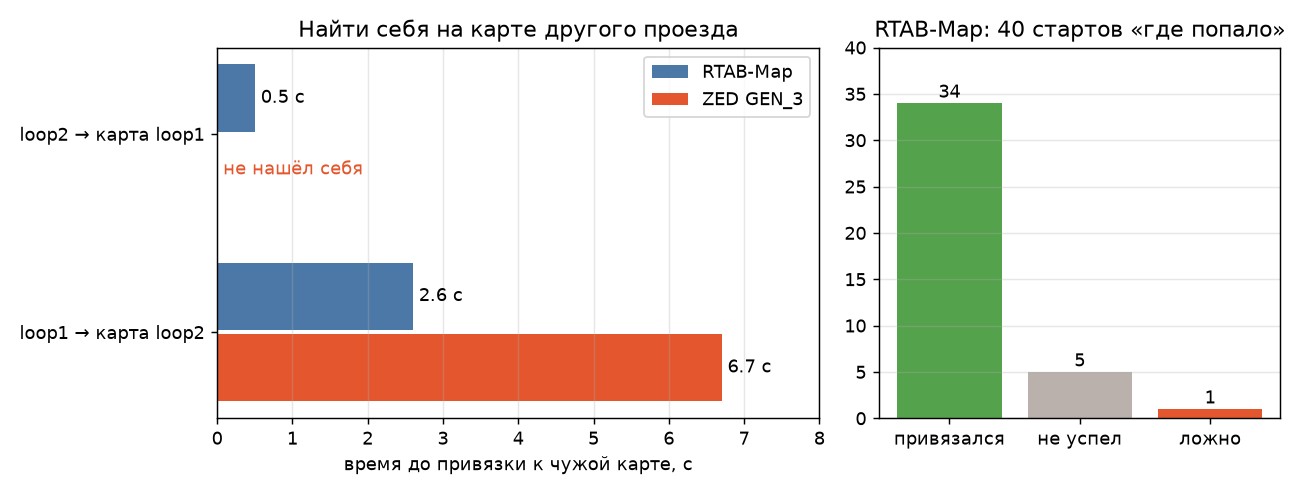
Said "let's rewrite everything", the robot isn't in production. First a benchmark on recorded drives. RTAB-Map finds itself on another drive's map in 0.5-2.6 seconds. GEN_3 manages it in 6.7 in one direction and not at all in the other. Out of 40 "switched on anywhere" starts RTAB-Map locked on in 35, once off by 86 cm. cuVSLAM computes odometry in 2.5 ms per frame. But there's no ground truth yet, so I need to stick marks of masking tape on the floor.