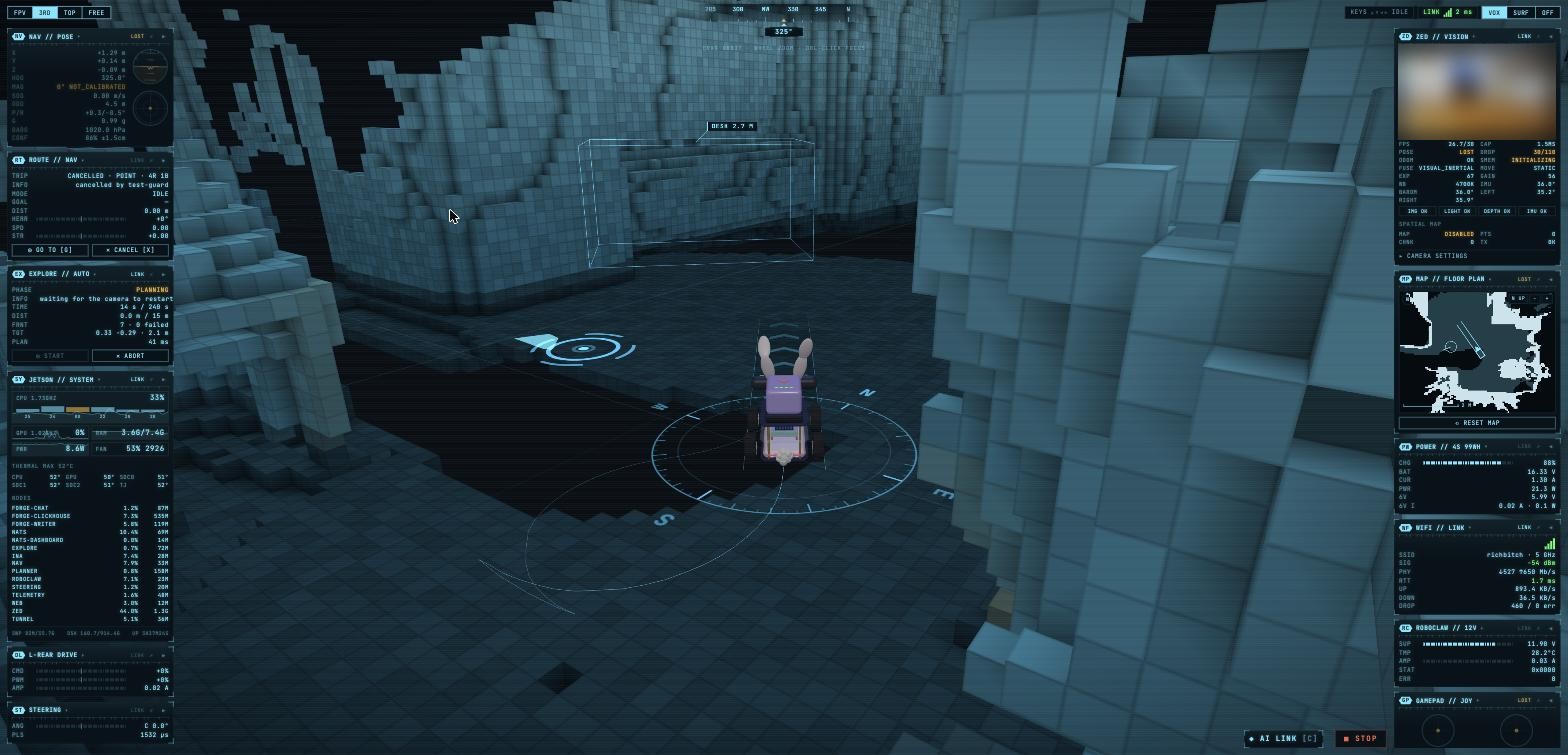
Put the robot on a table and watched it fall through the floor in the UI. The floor estimate assumed the wheels are always on the floor and moved up 69 cm together with the camera. Plus the glossy parquet and glass gave reflections, there was a whole mirror room under the floor. Now a new floor level is accepted only after driving a meter on it, and depth rays are clipped at the floor plane right in CUDA.
Also the map is now made of 5 cm voxels, just like the minecraft world I wrote about in #161. At first the robot was driving over bricks sticking out of the floor: the floor sat exactly on a voxel boundary and ±1 cm of noise pushed it into the row above. Shifted the grid by half a voxel and bricks went from 14% to 2%.