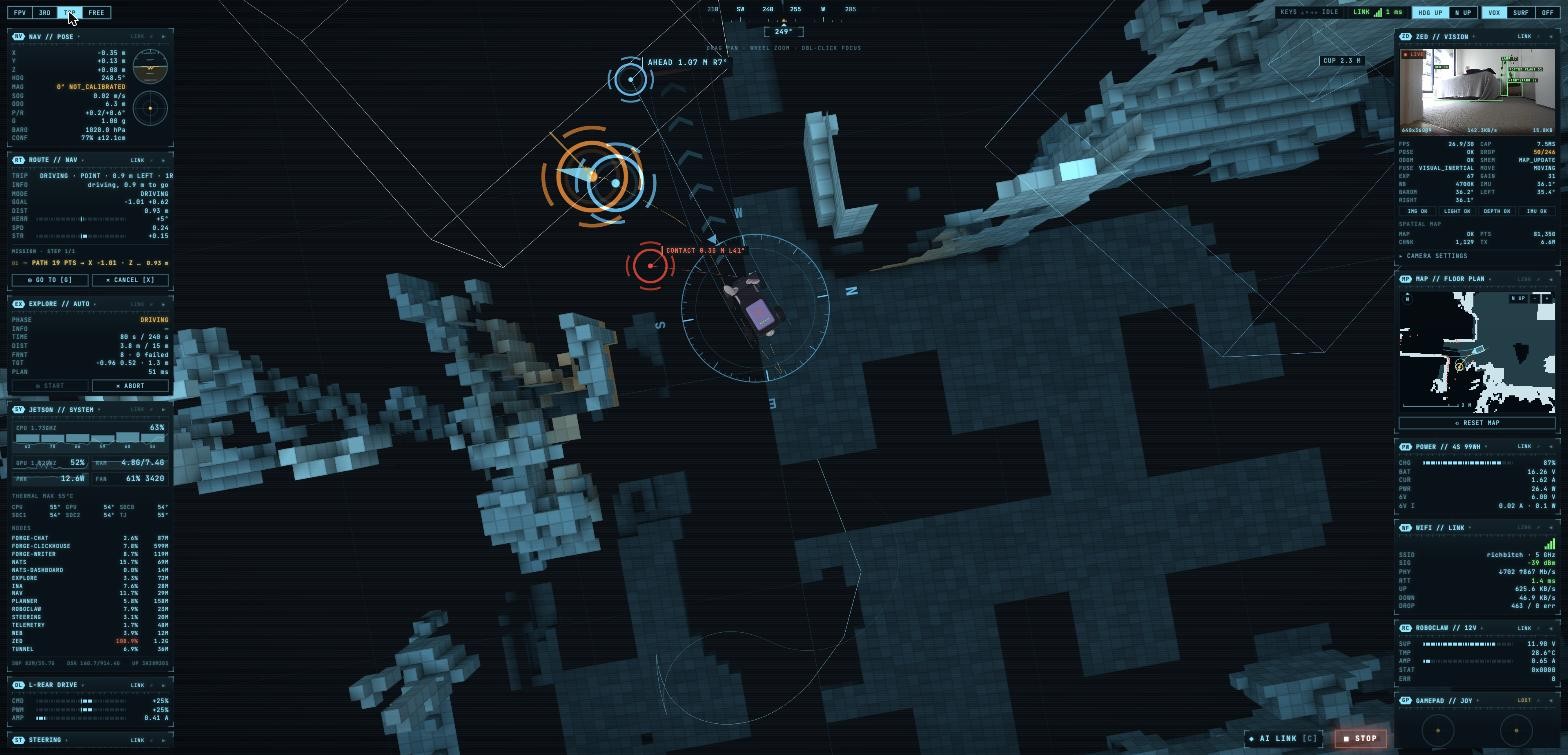
Asked for a command so the robot builds a map of the flat by itself. All the ready-made packages for this are tied to ROS, so our own again: frontier exploration and Hybrid A* for Ackermann with forward and reverse.
At first the robot didn't go anywhere at all. I had tuned the depth thresholds for a pretty map, and in front of a white wall in dim light the camera started throwing away 80-90% of points. The robot thought it was blind. I reverted the thresholds and it drove 6 meters in 46 seconds. A clean map and dense obstacles are fed by the same depth and you have to pick.