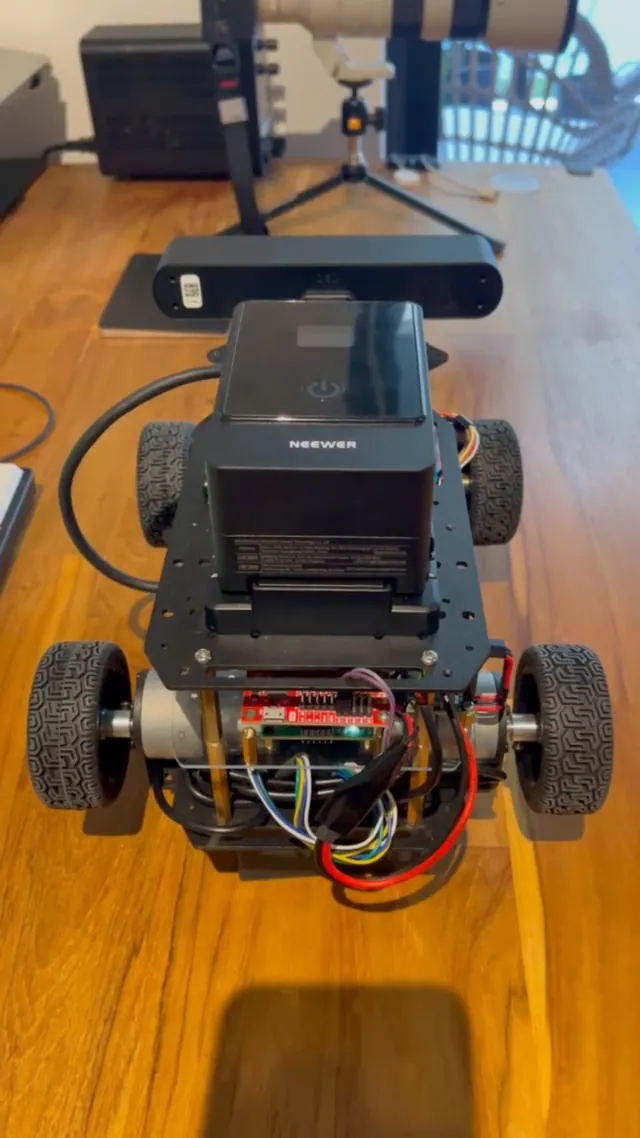
Got to the differential. Implemented and calibrated it. Now the turning radius is minimal and the wheels don’t slip when turning.

Robot Rabbit #163
translated from Russian
Got to the differential. Implemented and calibrated it. Now the turning radius is minimal and the wheels don’t slip when turning.