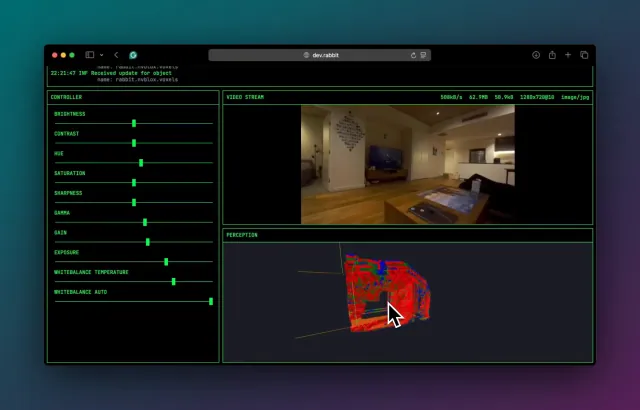
The next step was hooking up the vision pipeline to the robot. At first, I thought about writing the depth map and frames into a shared file but NATS easily handles a low-res stream. So in the end the camera sends rgb + depth to a topic and the nvblox node subscribes to them. For high resolution I’ll have to figure something else out but for now, it works. The camera intrinsics and pose get updated in the kv store instead of just sending them as messages to topics, which turned out to be much more convenient (even though under the hood it’s basically the same thing)
nvblox takes the depth and position and builds the tsdf (distance field to the surface) on the GPU in real time. It smoothes out noise, merges a lot of frames and gives you a map with free and occupied areas. From this you can get a voxel map just like a Minecraft world.