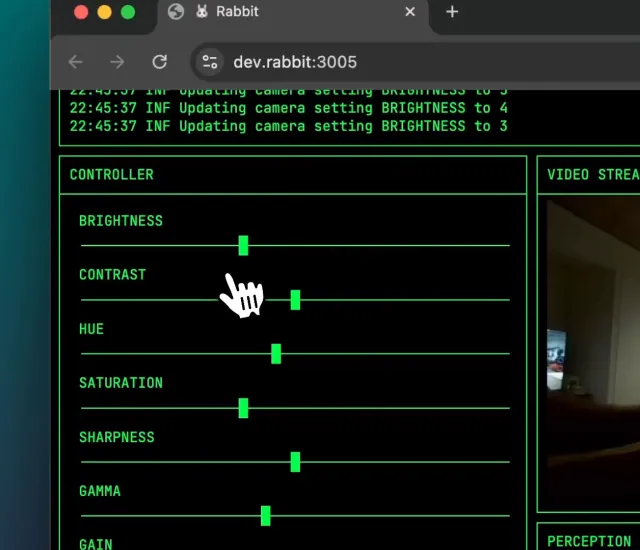
More and more I’m using NATS in the project. Threw together a simple UI to control camera settings from the UI. For this I decided to step away a bit from the idea of using pub sub for everything and take a look at jetstream. By default NATS core doesn’t have persistence but you can turn it on by enabling jetstream. Basically it’s just one flag and now you get a persistent KV store, object store and some delivery guarantees. All of this is super useful and really easy to use. For example camera settings are just a KV. Both the client and the robot subscribe to this key (in jetstream everything’s still just subjects) and can react to changes, both of them can also change the value and all clients instantly react to it and after restart the state is restored.

Robot Rabbit #158
translated from Russian