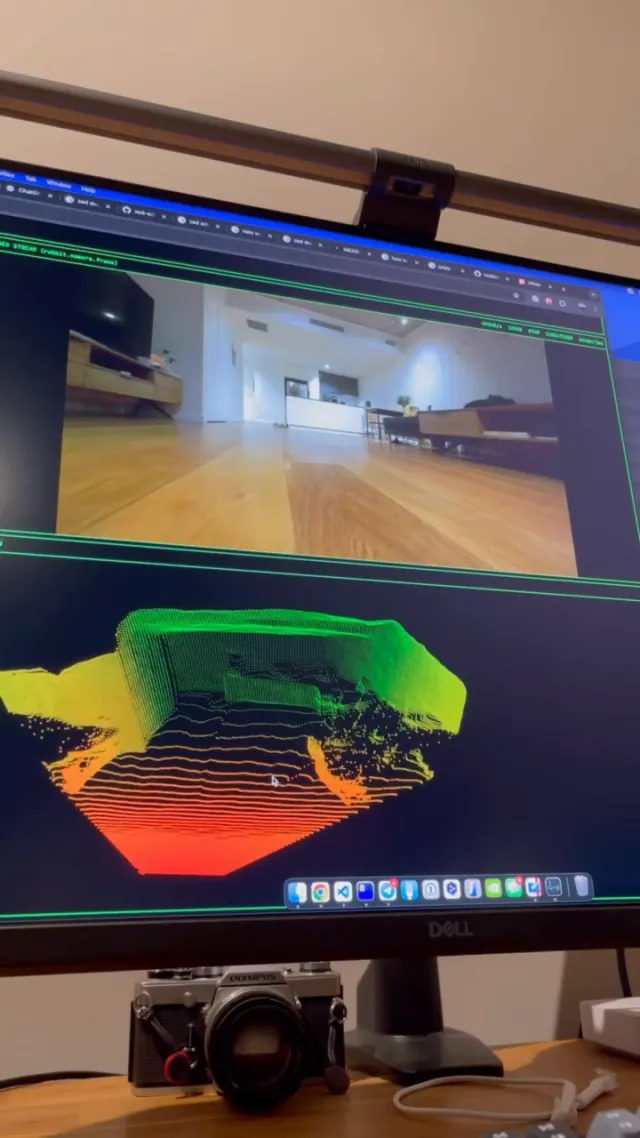
I couldn’t resist and decided to play around with points cloud and depth measurement. For now I tried the lightest model.
What you see at the bottom of the screen isn’t SLAM yet, it’s just a stateless point cloud that gets published from the robot to nats at 30hz and drawn using treejs in the browser. The further a point is, the greener it gets. That’s just for convenience but in code it’s just a 3 or 4 dimensional matrix (4 if you want to keep the original camera color)
Turns out the tricky part is that 1280x720 is way too heavy and just the raw byte blob of this matrix is 70+Mb. Pumping such an array 30 times a second is impossible because of the 64Mb per message limit and bandwidth restrictions. After dropping the resolution to 320p and compressing it with zlib, I managed to get a couple hundred kilobytes which seems ok. Plus this matrix is sparse so you could also cut out the zeros. Maybe it doesn’t even make sense if you compress anyway.