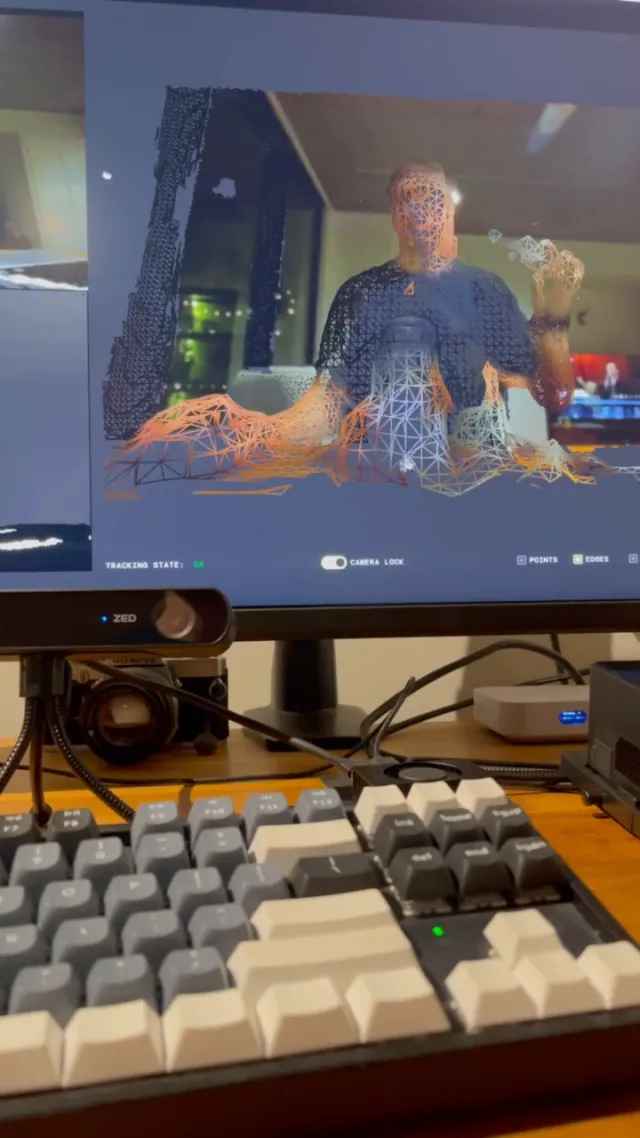
The SDK has models for building point clouds that will be useful for SLAM (simultaneous localization and mapping) when the robot figures out its position and maintains a map of the area.

Robot Rabbit #131
translated from Russian